Intelligence that survives contact with reality.
ACTORA combines spatial perception, local reasoning, tactile feedback, motion control and adaptive safety in one deterministic physical intelligence stack.
01 / ARCHITECTURE
Five interlocked subsystems.
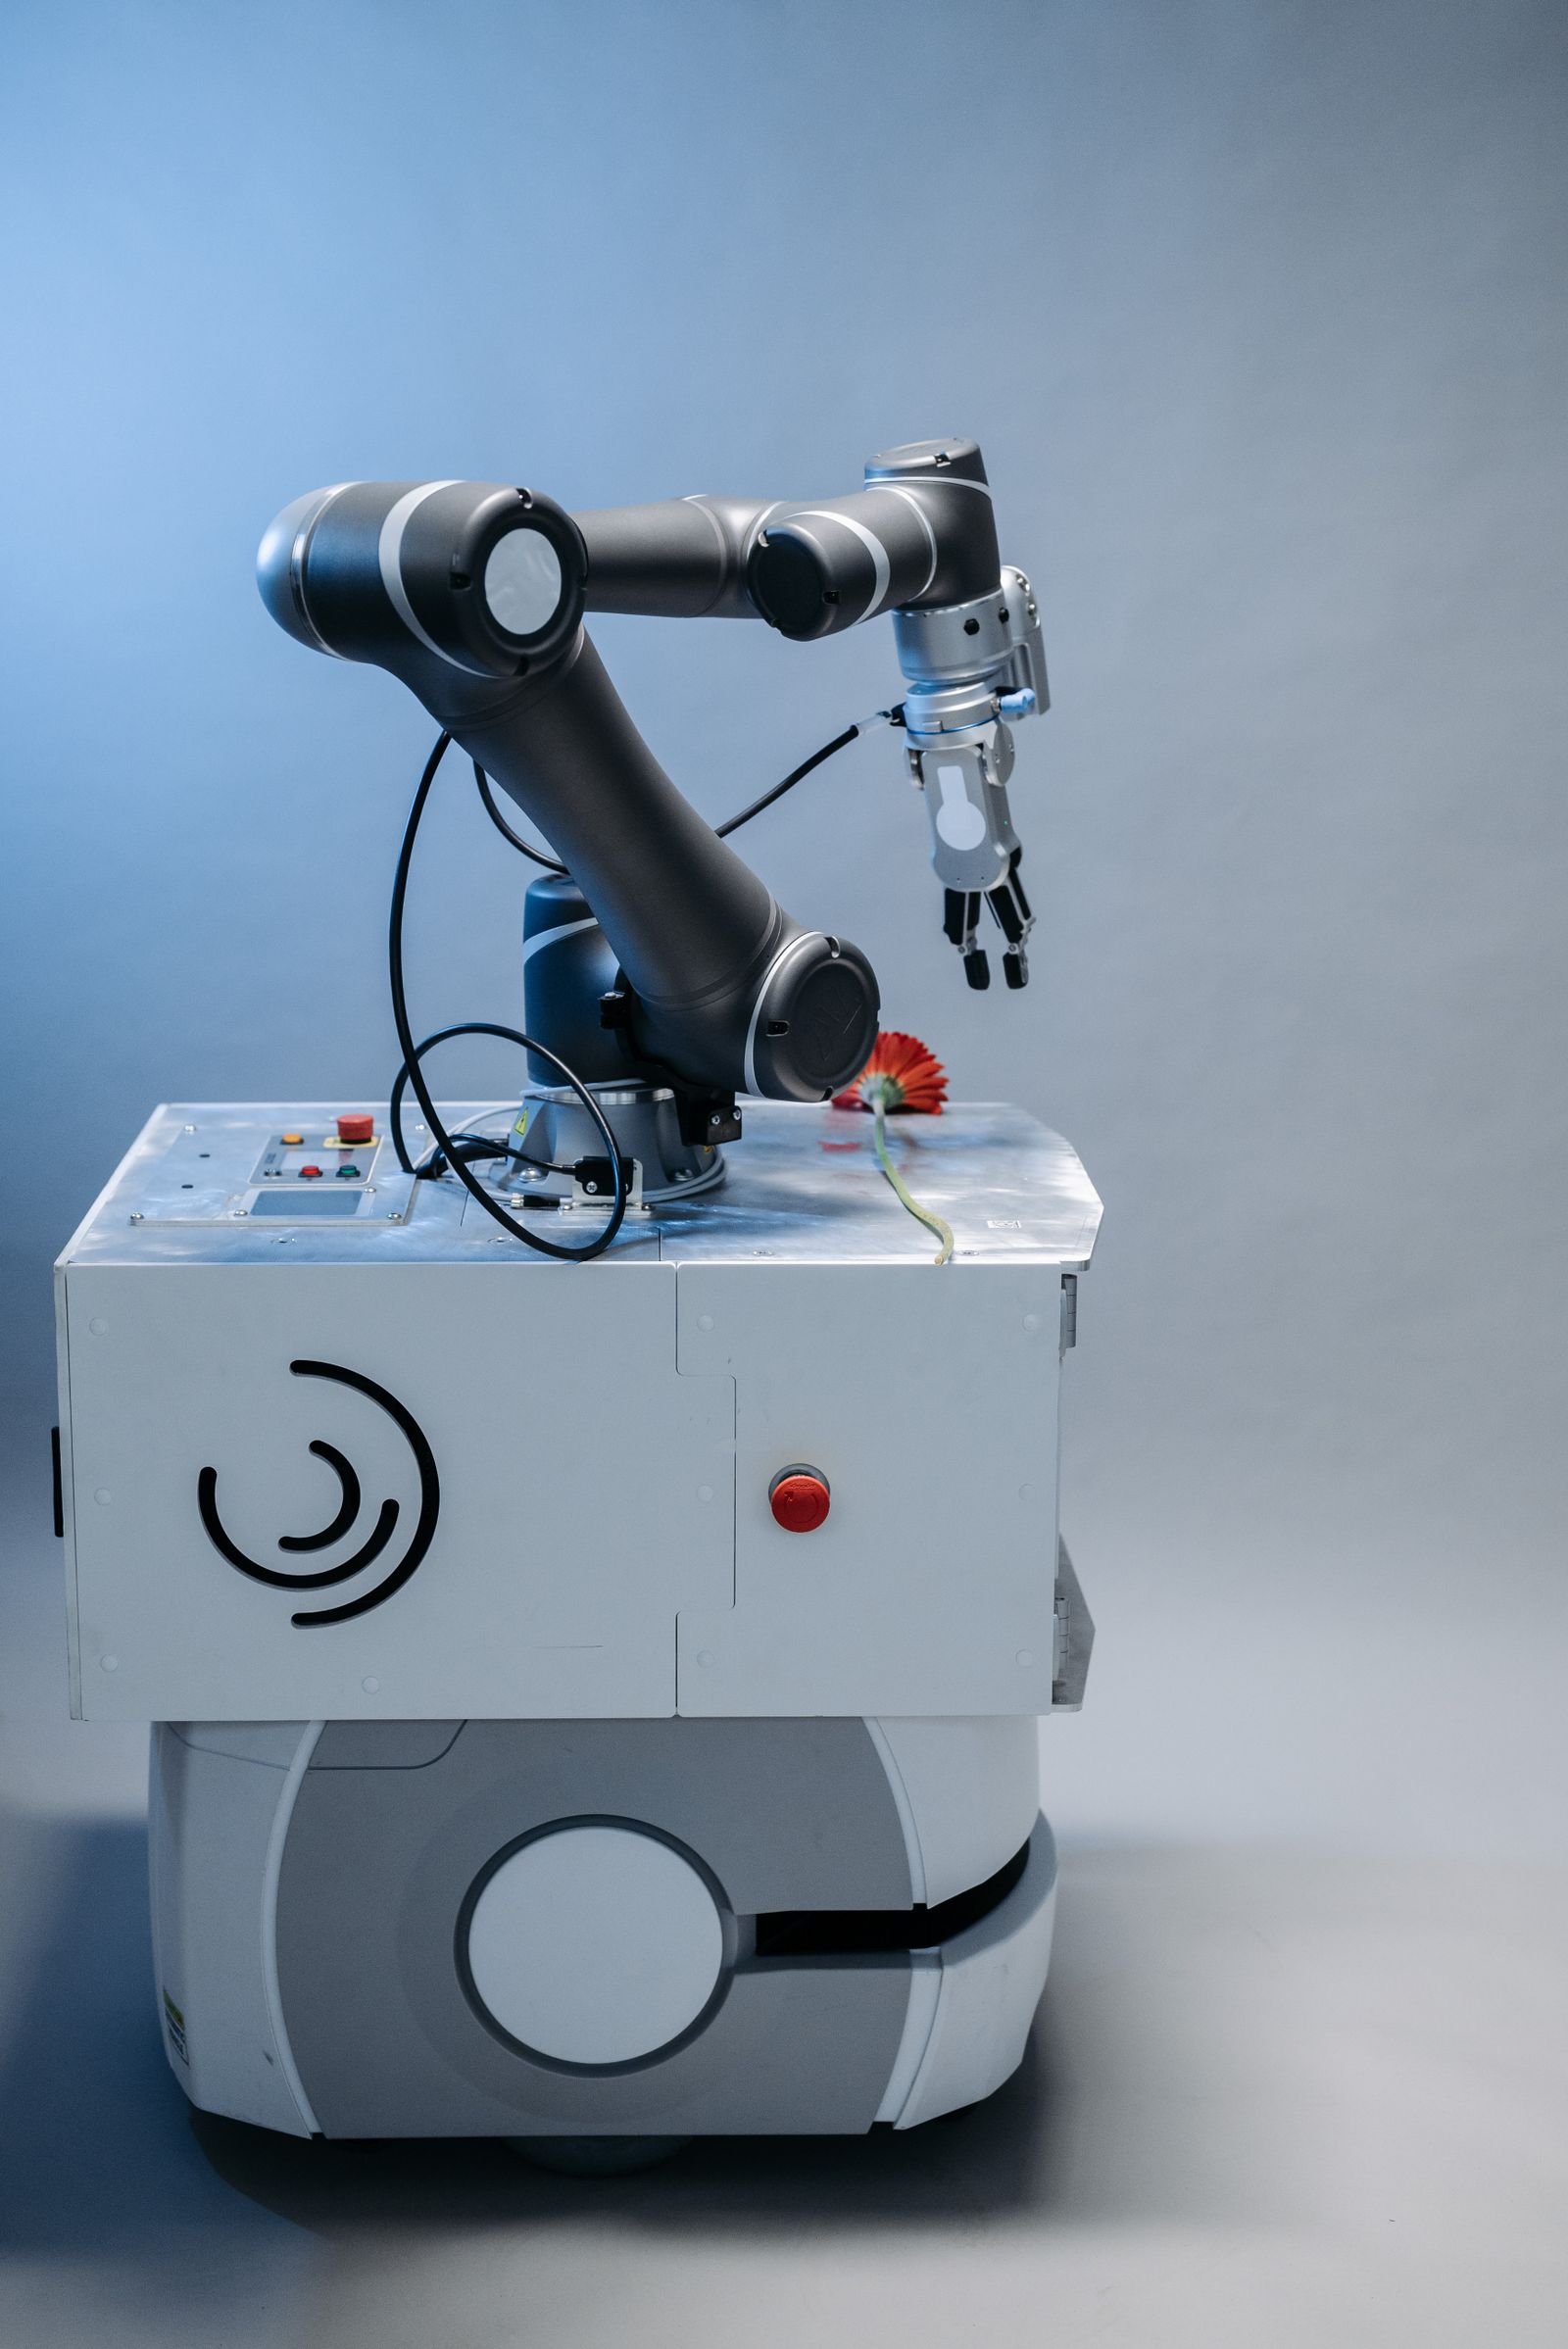
Spatial perception
Depth, proximity and scene context merge into a local world model.
Task cognition
Models interpret task intent and choose bounded actions.
Tactile feedback
Force and contact data verify what the model predicted.
Motion execution
Trajectory and torque control coordinate physical output.
Adaptive safety
Limits and operator intent are checked before every response.
02 / OPERATING STACK
Modular enough to inspect. Integrated enough to move.
Vision + sensing
Time-aligned depth, object context, force and motion cues for a stable field model.
Edge cognition
Task policies and planning stay near the machine to keep latency bounded.
Motion control
Real-time trajectories, torque and tactile response coordinated in a single loop.
Safety governor
Operator zones, machine limits and environment changes verified continuously.
03 / VERIFICATION
Measured inside the loop.
Put the stack against a real constraint.
Describe the environment, target behavior and performance boundary. We will map the relevant control architecture.
Start engineering inquiry →