
01 / INDUSTRIAL
Adaptive production
Assembly, inspection and manipulation inside changing cells and mixed workflows.
Edge-native perception, reasoning and control for autonomous systems that need to work inside changing physical environments.
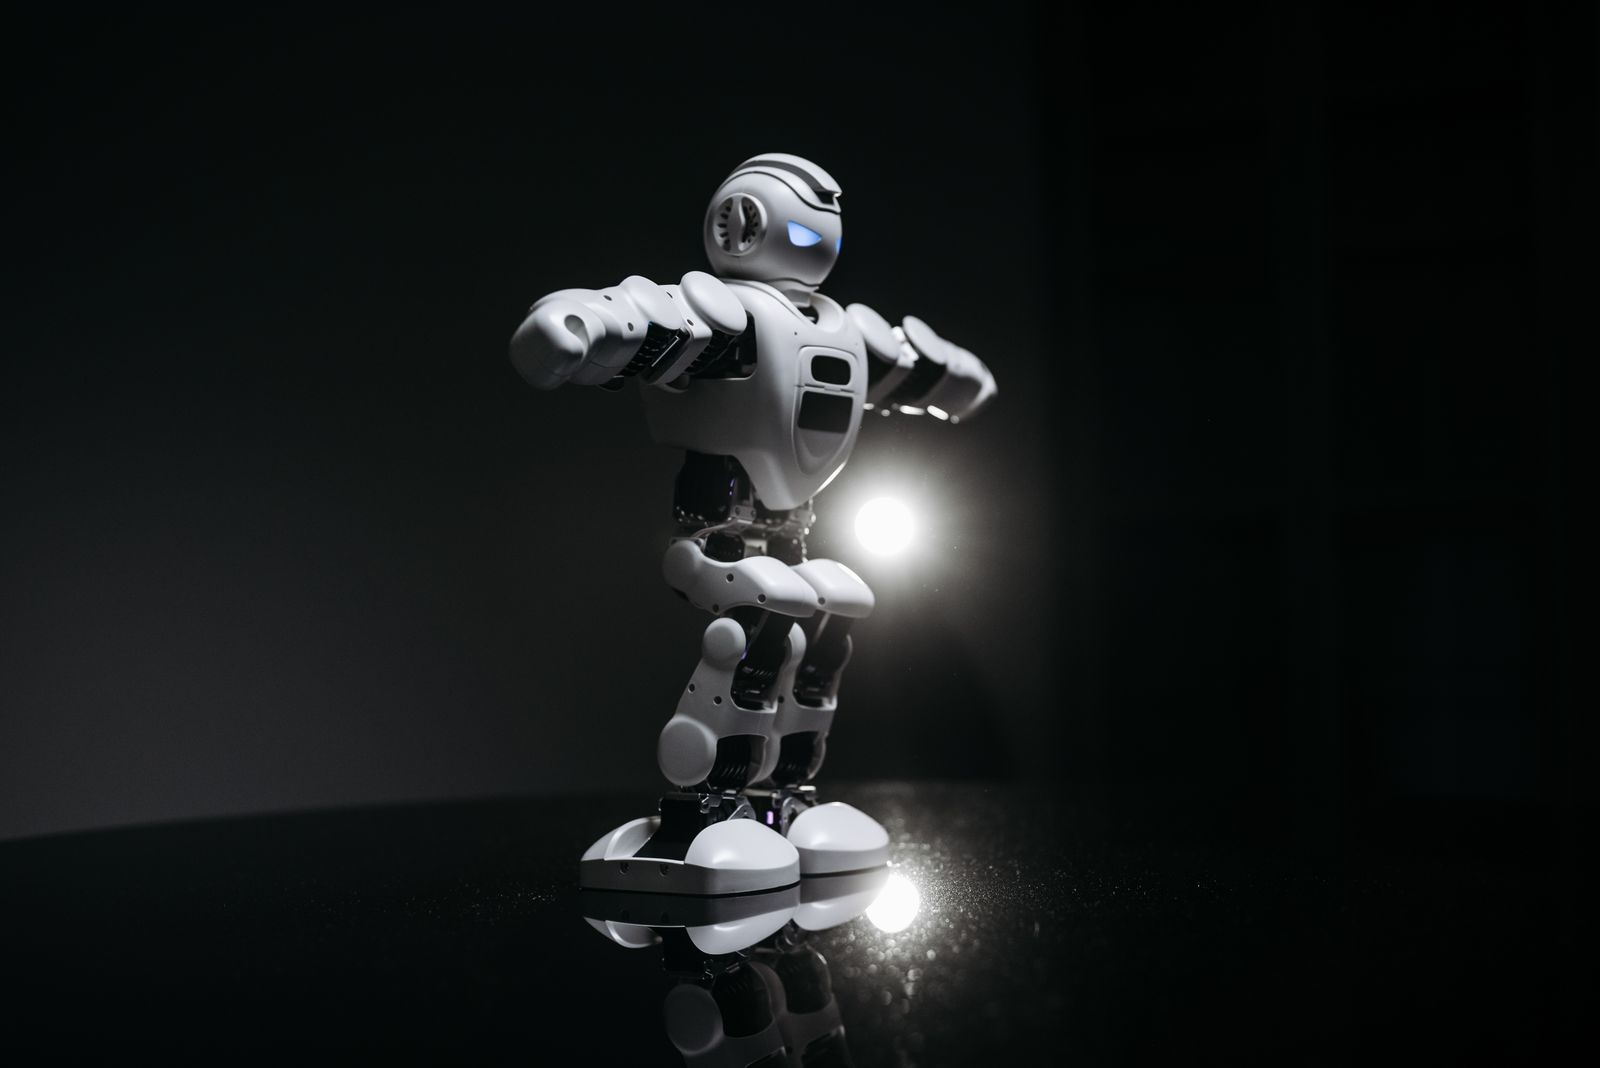
Software stops at the screen. Physical intelligence starts after it.
ACTORA connects sensing, on-device reasoning and deterministic motion into a single field-ready loop. The result is a machine that can interpret the environment, choose an action and move with bounded behavior.
02 / SYSTEM ARCHITECTURE
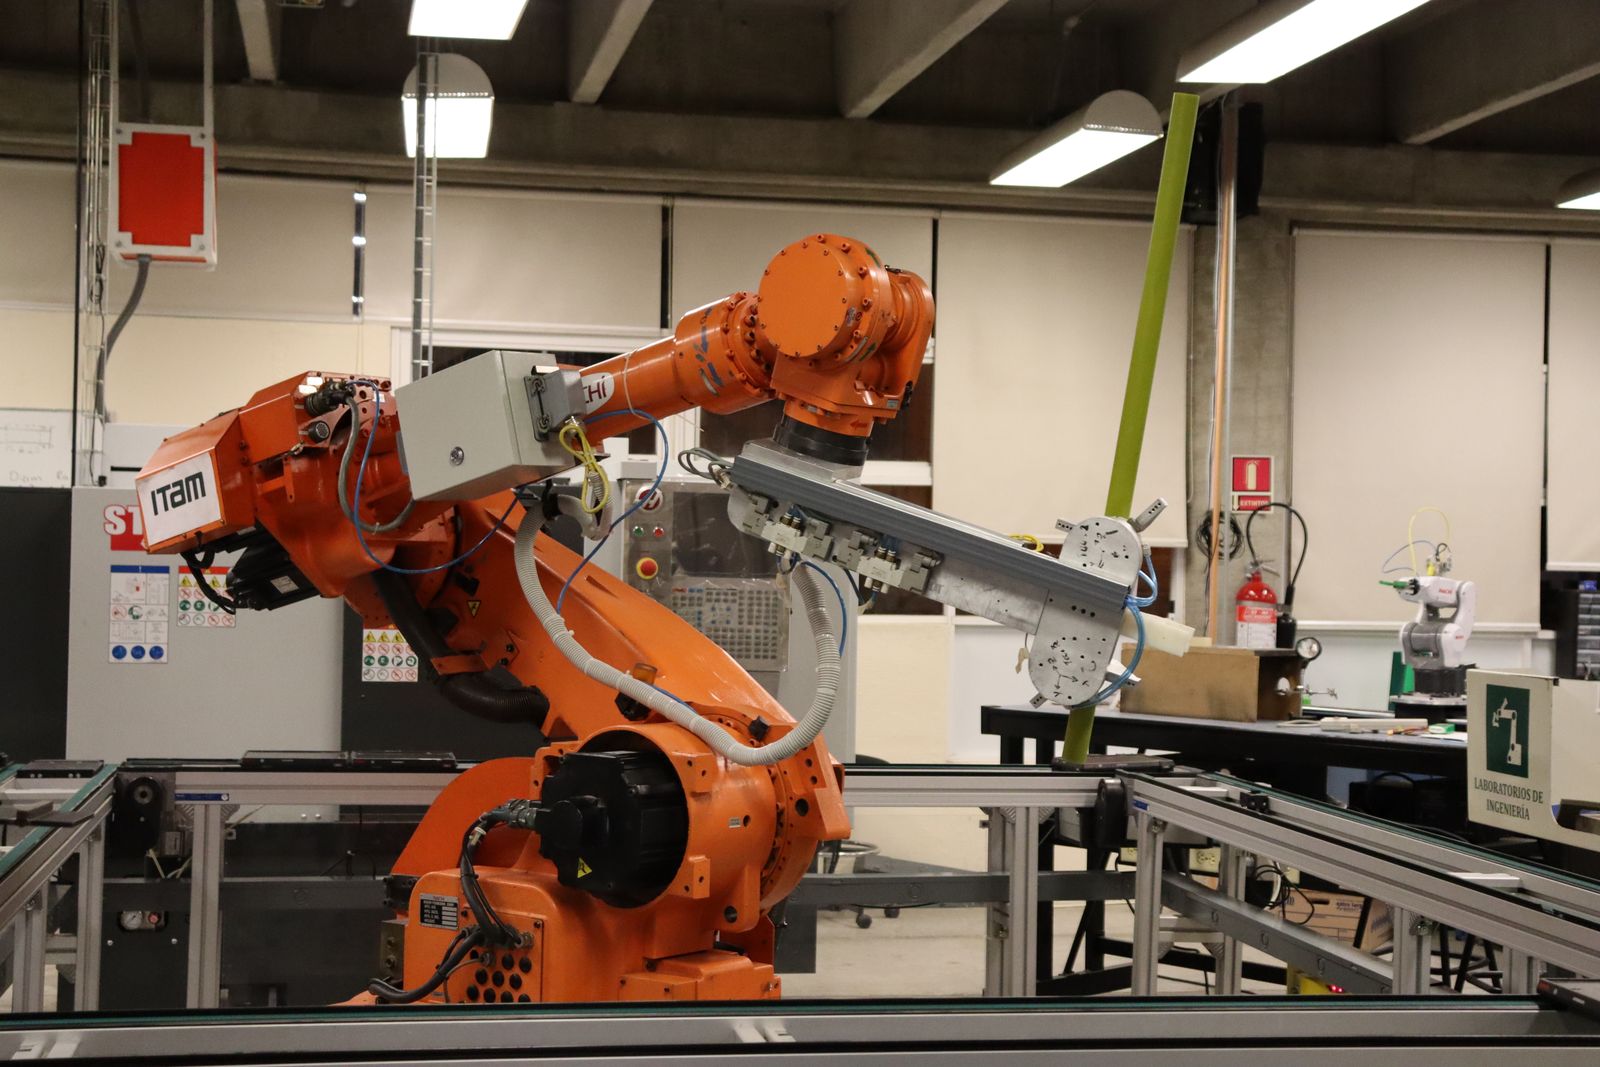
Vision, depth and proximity are fused into one local field model.
Policies and task intent resolve locally without cloud latency.
Contact and force close the gap between prediction and reality.
Motion plans convert into precise, bounded mechanical output.
Limits, human proximity and operator intent are checked continuously.
03 / CAPABILITY LOOP
Multimodal sensing turns physical scenes into structured local context.
On-device inference chooses actions with bounded latency and policy limits.
Deterministic motion control keeps trajectories stable under changing loads.
Continuous feedback refines the next response without losing operator control.
04 / DEPLOYMENT FIELDS
Assembly, inspection and manipulation inside changing cells and mixed workflows.

Autonomous routing and handling where people, inventory and constraints keep moving.
Reconfigurable stacks for advanced robotics, manipulation and embodied AI research.
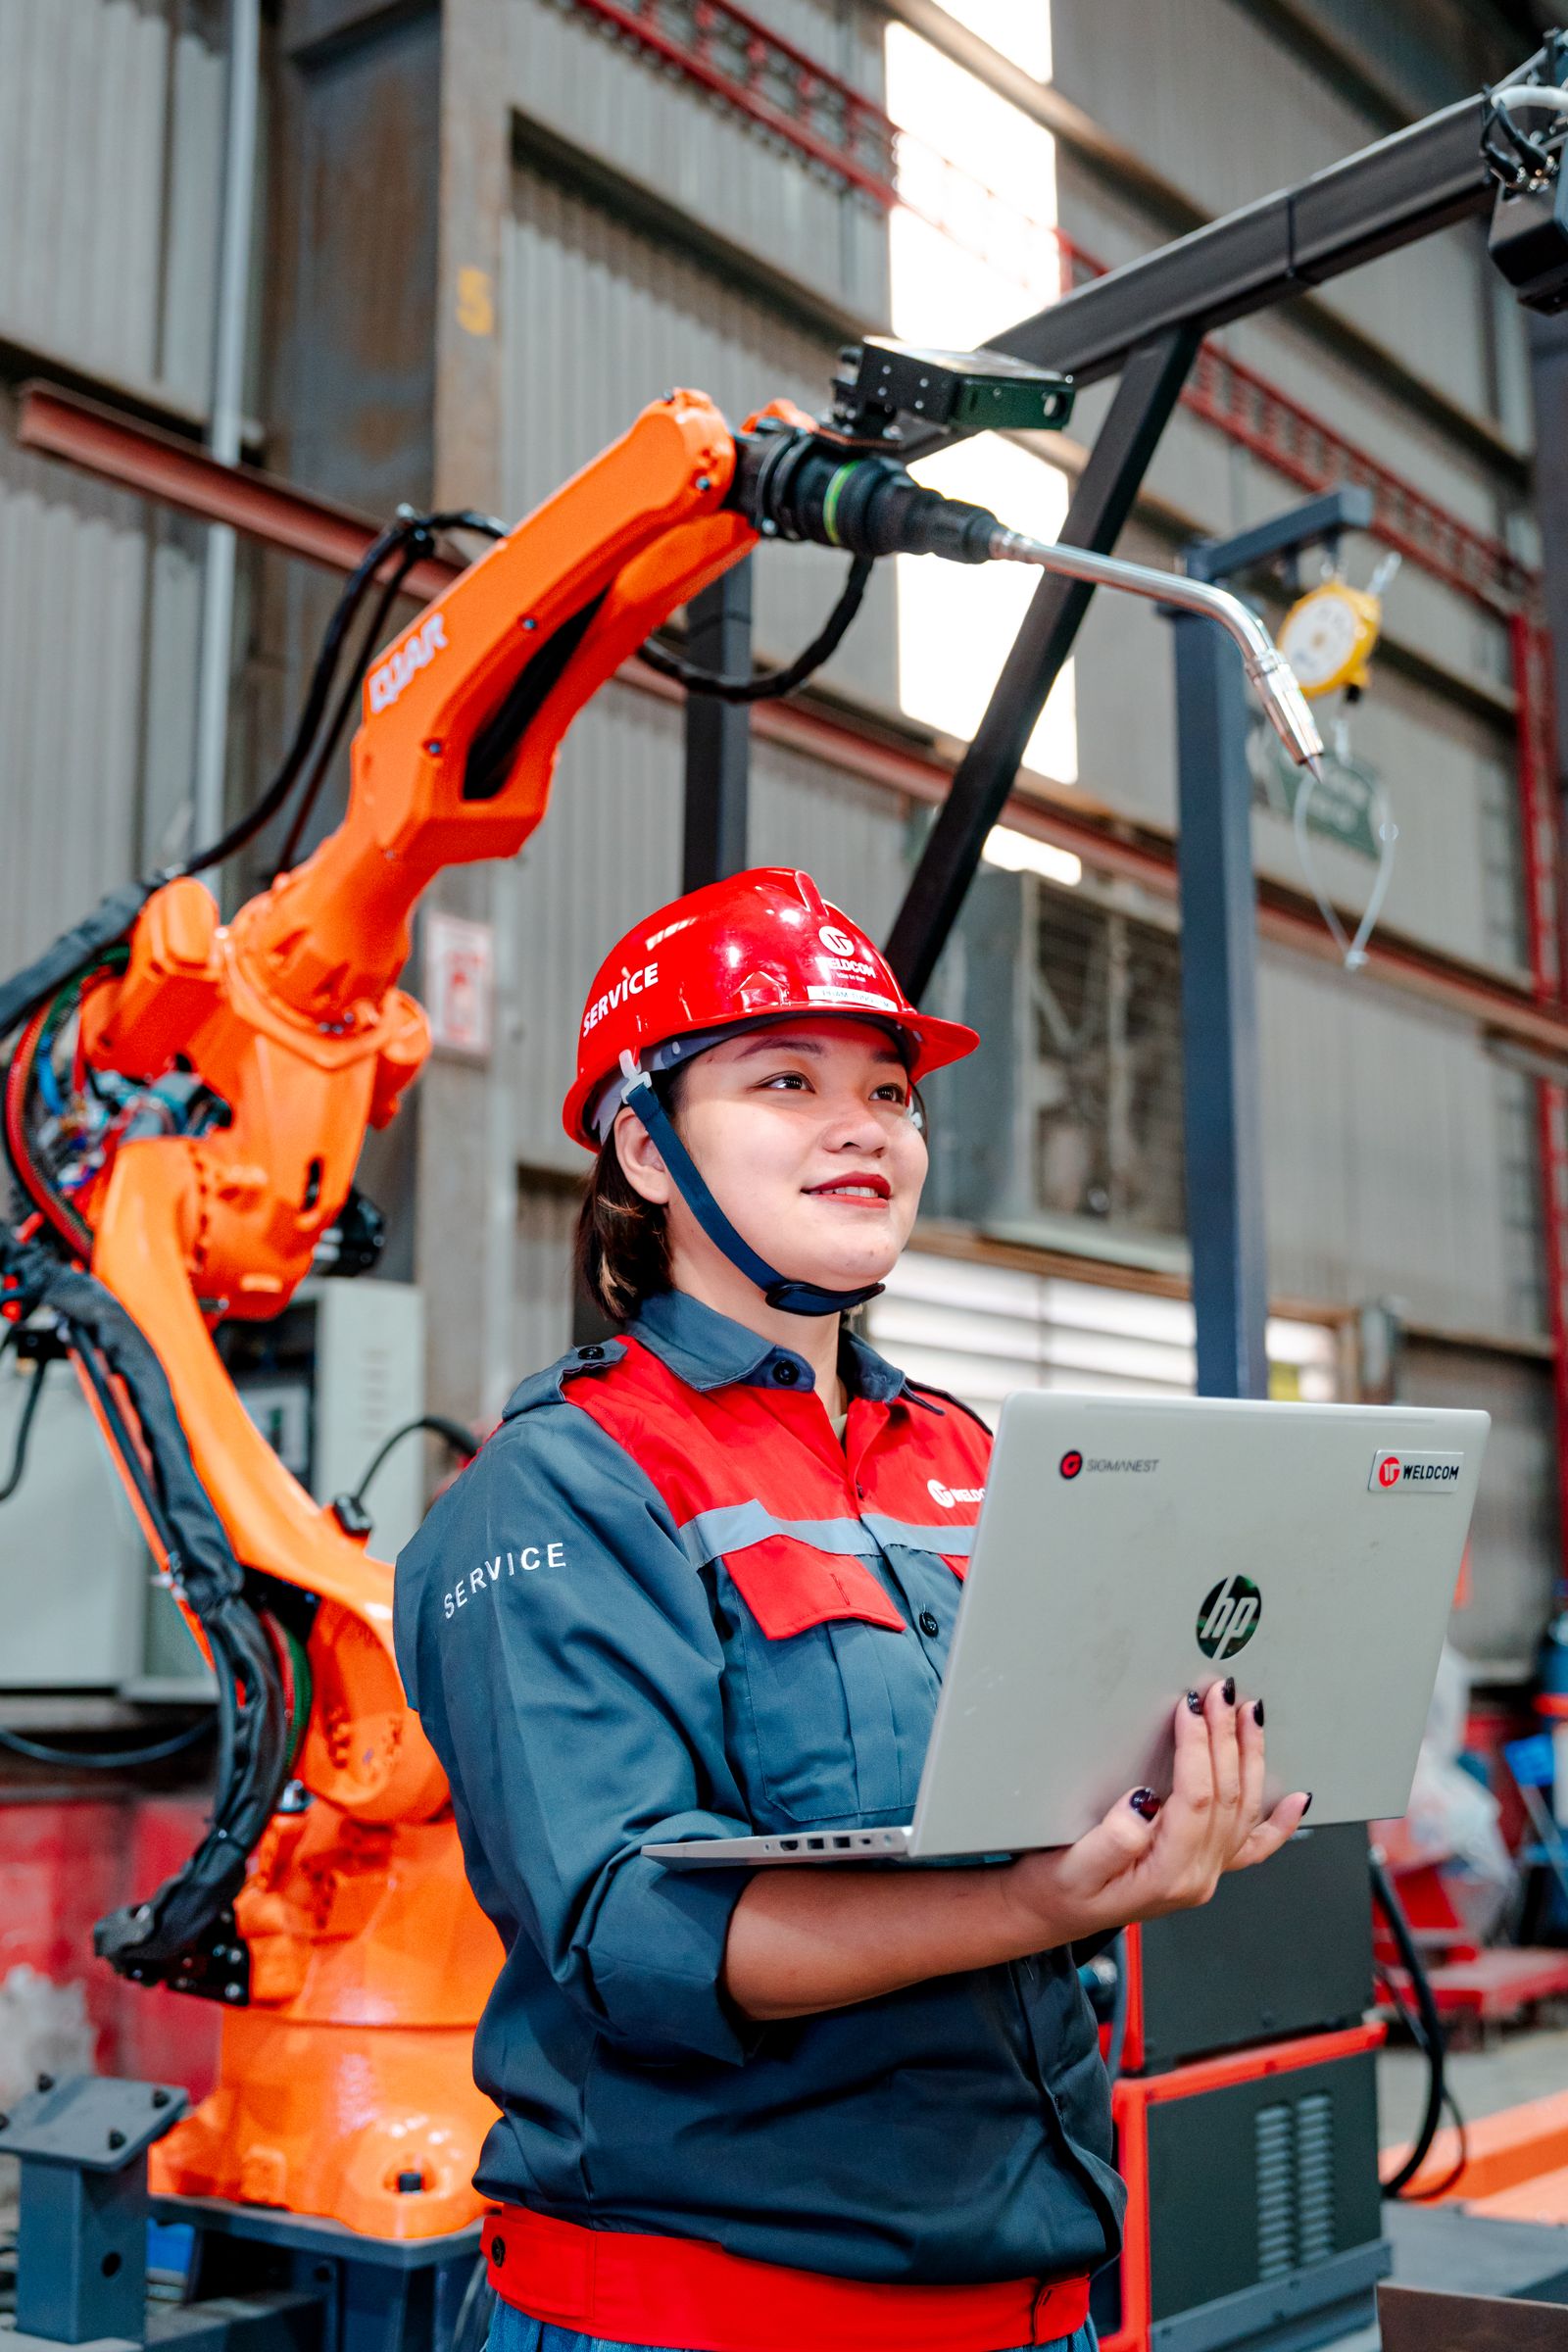
Machine behavior designed to remain predictable, inspectable and useful beside operators.
Physical intelligence matters only when it expands human capability. ACTORA systems prioritize human agency, clear operating states and predictable failure boundaries.
06 / PRODUCT VIEW
Bring us the environment, the task and the constraint. We will map the physical intelligence loop around the problem.
Request field review →